 |
Speeduino
|
Loading...
Searching...
No Matches
|
Speeduino
|
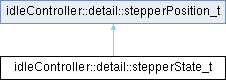
Captures the state of the stepper motor. More...
#include <stepper.h>
Public Member Functions | |
| stepperState_t ()=default | |
| stepperState_t (const pinNumbers_t &pins, const config9 &page9) | |
Public Attributes | |
| uint16_t | targetStep = 0 |
| The target step we want to move to | |
| uint32_t | startTime = 0 |
| The time in µS that we started the current phase. | |
| outputPin_t | pinStepperEnable |
| outputPin_t | pinStepperStep |
| invertableOutputPinAdaper_t< outputPin_t > | pinStepperDir |
 Public Attributes inherited from idleController::detail::stepperPosition_t | |
| uint16_t | curStep = 0 |
| The current location of the motor. | |
| uint16_t | completedHomeSteps = 0 |
| Number of homing steps completed. | |
| StepperStatus | status = StepperStatus::OFF |
| What phase the motor is in. | |
Captures the state of the stepper motor.
|
default |
| idleController::detail::stepperState_t::stepperState_t | ( | const pinNumbers_t & | pins, |
| const config9 & | page9 | ||
| ) |
| invertableOutputPinAdaper_t<outputPin_t> idleController::detail::stepperState_t::pinStepperDir |
| outputPin_t idleController::detail::stepperState_t::pinStepperEnable |
| outputPin_t idleController::detail::stepperState_t::pinStepperStep |
| uint32_t idleController::detail::stepperState_t::startTime = 0 |
The time in µS that we started the current phase.
| uint16_t idleController::detail::stepperState_t::targetStep = 0 |
The target step we want to move to
 1.9.8